Agricultural robots are getting smarter, but are they really reliable? At the recent Vision + Robotics Parcours (Wageningen) and Smart Farming Pavilion at Agrotechniek Holland (Biddinghuizen) in September, I saw firsthand how AI, computer vision, advanced sensing and autonomous navigation are enabling machines to tackle increasingly complex agricultural tasks. Yet, as impressive as these field demonstrations are, can these machines keep working in unpredictable farming conditions?
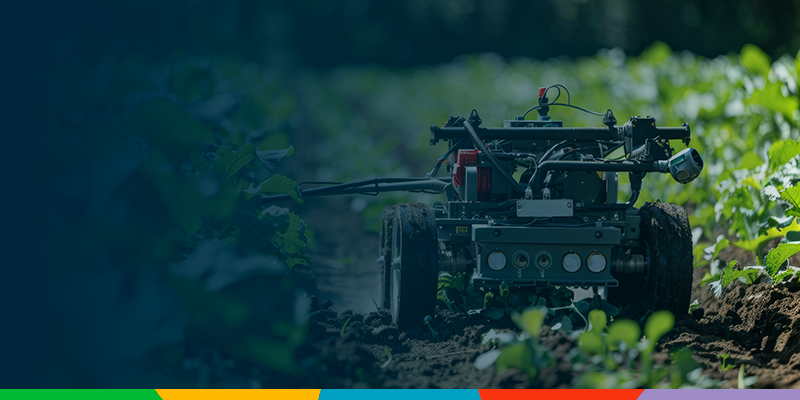
A successful demo is not a reliable product
In a working farm, you’ll encounter different crops, varying terrain, unpredictable weather and differing skills of human operators. These factors interact in unpredictable ways, meaning a vision system that performs perfectly in morning sunlight can easily fail when dust hits the sensors during an afternoon harvest.
The engineering challenge is not just to make robots smarter, but to make them predictable, resilient and manageable beyond controlled environments. Teams may find themselves running endless edge case tests, expanding validation programs, redesigning sensors and perception systems, investigating field issues that are difficult to reproduce, and struggling to determine when the machine is truly ready for deployment.
Smarter shouldn’t mean more work
The promise of agricultural robotics is simple: take work off the farmer’s hands. But when a machine is not ready for the conditions it encounters, that promise can quickly be reversed.
A robot that needs frequent supervision, manual intervention or troubleshooting may be autonomous on paper, but still creates work in practice. Farmers may have to monitor its performance, step in when it gets stuck, correct errors, manage exceptions or adapt their workflow around the machine. The technology should adapt to the realities of the farm, not require the farmer to constantly adapt to the technology.
Strategic principles for engineering reliability
Making agricultural robotics reliable is not about eliminating every unexpected scenario. Once deployed in the field, that is simply impossible. It is about building systems and processes that can identify uncertainty, learn from it and respond safely:
-
Turn edge cases into a structured learning process
Edge cases aren’t isolated failures, they are valuable signals about where a system still lacks robustness. But R&D teams shouldn’t have to wait for every failure to happen before they can learn from it.
Synthetic user personas allow development teams to anticipate how operators, especially those less tech-savvy or working under high-stress field conditions, interact with new machinery interfaces. By modeling these human-machine interaction risks alongside synthetic environmental edge cases, teams can refine user workflows and system prompts well before field testing.
Want to explore this approach further? Our webinar on accelerating product development dives deeper into how AI, synthetic users and LLMs can help teams accelerate innovation while reducing risk.
-
Design for safe failure and continuous validation
No autonomous system will perform perfectly in every situation. The question is what happens when it encounters something it does not understand.
Robust agricultural robots need clear fallback behaviors, safe failure modes and mechanisms for handling uncertainty. But these cannot be designed and tested once and then considered done. Simulation, laboratory testing and field operation should form a continuous feedback loop, where every new scenario helps refine requirements, improve the system and strengthen the next round of validation.
The result is a machine that learns from every testing cycle, making it more resilient to the conditions it will face in the real world.
-
Deploy autonomy incrementally
By automating specific tasks or operating within defined conditions first, teams can build confidence, gather real-world data and expand the system’s capabilities step by step. This also makes it easier to identify where autonomy delivers real value and where human oversight is still needed.
Aiming for unassisted autonomy from day one rarely works in unpredictable field conditions. This safety-first reality was highlighted during the Vision + Robotics event, where an autonomous harvester was demonstrated with a human supervisor seated inside, specifically to manage safety risks during operation. Taking an incremental approach allows engineering teams to satisfy strict safety requirements, validate perception edge cases in real conditions, and build proven reliability before removing human oversight entirely.
-
Build the infrastructure to support learning in the field
Reliable autonomy depends not only on the robot itself, but also on the infrastructure around it. Virtual training environments can help greenhouse robots learn from a wider range of scenarios before deployment. Live vision can support harvesting robots in adapting to changing conditions. And strong remote service capabilities can help teams monitor, diagnose and improve machines once they are in the field.
This approach becomes even more powerful when machines are connected. Instead of farmers managing each device individually, linked devices can share data, coordinate tasks and work together as part of a wider ecosystem.
But building reliable connected systems needs a digital backbone that can keep up. Learn how to build one that is reliable, scalable and maintainable through our webinar.
From smart to trusted
Farmers don’t buy “smart” robots, they buy robust and durable machines that get the job done day in and day out. Achieving that level of trust demands more than clever algorithms. It requires a disciplined product development process that respects field conditions, manages risk methodically, and prioritizes long-term performance over a short-term spectacle.
If you’re ready to bridge the gap between initial innovation and field-ready reliability, let’s connect. Together, we can refine your product roadmap, manage engineering risk, and build trusted solutions that lead tomorrow’s agricultural market.